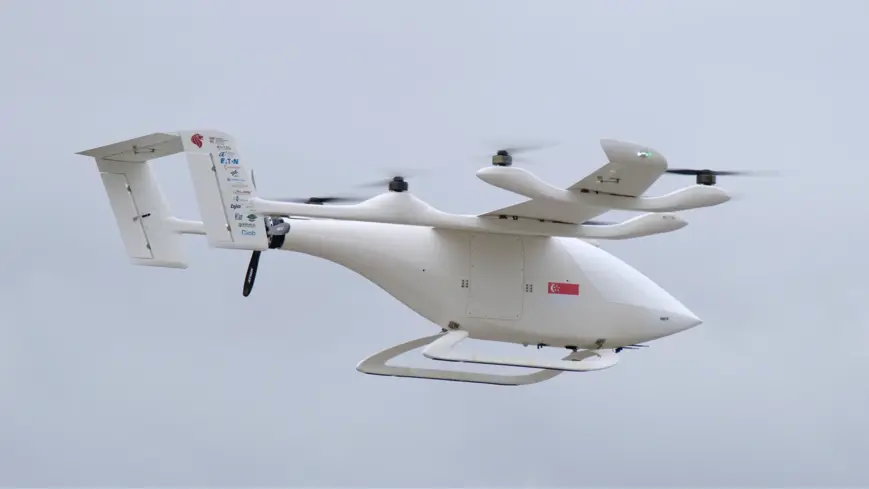
Veronte Autopilot 4x 2.2 builds on the proven triple-redundant 4x architecture and takes it much further, with ten times the processing power and memory, dissimilar processors, dual channel redundant I/O and power, native ARINC 429 and TSN Ethernet, and distributed redundancy. It is designed for DAL A certification.
Alicante, Spain, November 12, 2026: Embention today announced Veronte Autopilot 4x 2.2, the latest version of its triple-redundant flight control computer for defense drones, civil drones and eVTOL. The 4x 2.2 is available for order now.
A major step forward for the 4x
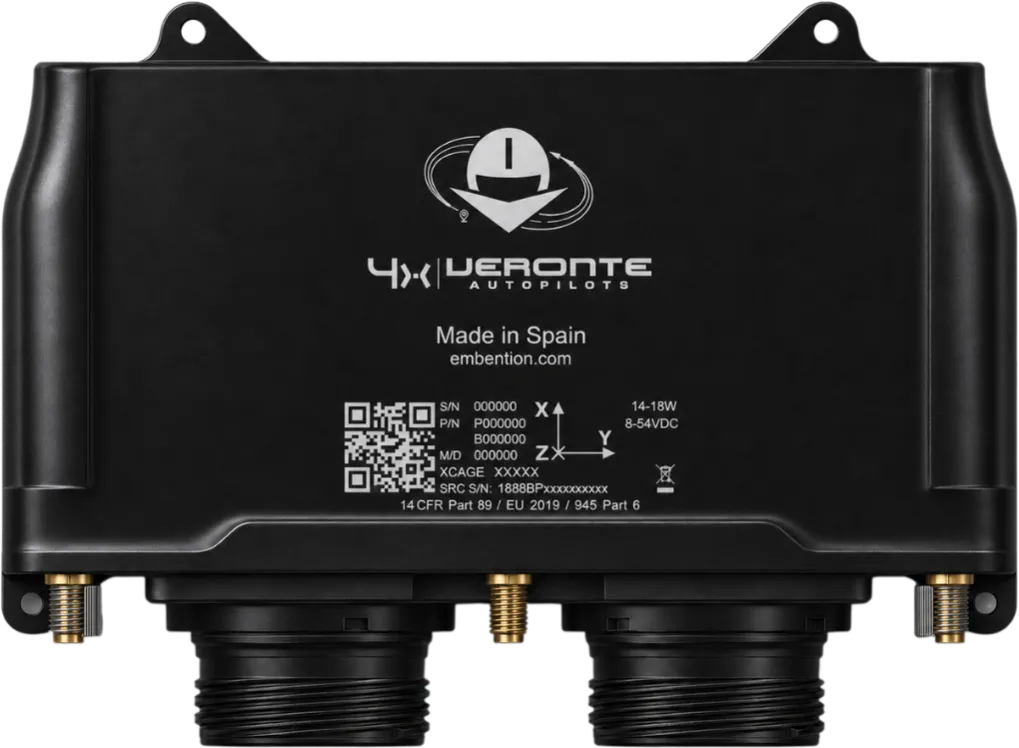
The 4x 2.2 keeps the flight-proven Primary, Monitor and Recovery architecture: three independent lanes in a single unit, each with its own guidance, navigation and control. Compared with the 4x 1.8, each part has been upgraded: ten times the processing power and memory, dissimilar processors, enhanced sensor suite, four power inputs from 8 to 54 VDC, ARINC 429, two TSN Ethernet ports, eight CAN FD buses and SAIL Bus. ADS-B and SRC (Short Range Communications) are included. SRC works as Remote ID, in conformity with FAA 14 CFR Part 89 and EU Regulation 2019/945, or for swarming and formation flight.
Redundancy and certification
Every bus is duplicated on two MIL-DTL-38999 connectors, so the loss of a harness, a connector or a power rail does not interrupt flight control. A single unit or several units in distributed redundancy can be used in any aircraft, from tactical UAS to eVTOL and manned fly-by-wire aircraft. The 4x 2.2 is designed for DAL A: software with a single unit and hardware with two units. Development follows DO-178C, DO-254 and ARP4754B, with an extended DO-160G environmental qualification, for FAA Part 23 and Part 25 aircraft, powered lift under EASA SC-VTOL and certified UAS.
“Certified programs need a flight control computer that is ready for certification from the start. The 4x 2.2 is designed for DAL A, with ten times the processing power for more demanding control laws and custom code, and dissimilar processors with redundant I/O and power for higher reliability,” said Javier Espuch, Chief Business Development Officer at Embention.
Veronte platform software runs on all three lanes. The application software can be Veronte flight software, custom C/C++ or Simulink code on a dedicated processor core, or a complete third-party flight software on the Primary lane, monitored by Veronte software on the Monitor and Recovery lanes. With Veronte flight software, the 4x 2.2 is ready to fly. Its control laws condense Embention’s experience flying unconventional aircraft layouts, so each aircraft is set up through configuration, without a long development process customized for each airframe. In all cases, control laws and intellectual property stay with the aircraft manufacturer.
For defense, civil drones and eVTOL
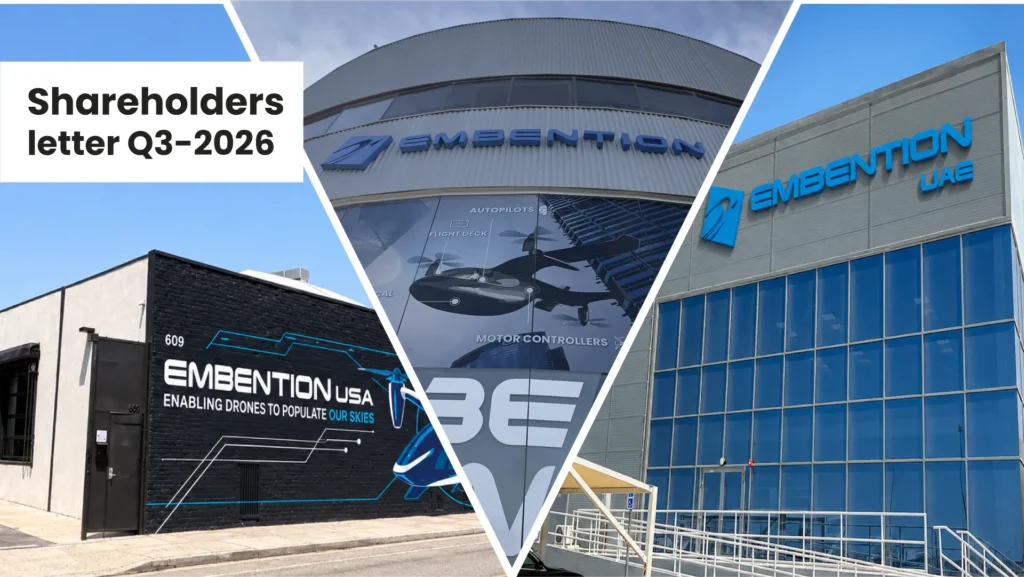
For defense programs, the 4x 2.2 is built in several manufacturing locations (Spain, UAE, US and Austria) with components from trusted supply chains, and is designed for NDAA compliance and the Blue UAS list. For civil drones, it supports certified and high-SAIL operations. For eVTOL, it provides a fly-by-wire architecture designed for certification.
“The 4x 2.2 brings together 19 years of flight experience with unconventional vehicles and of certification work with authorities. Each improvement in this version comes from lessons learned in flight and in certification programs,” said David Benavente, CEO of Embention.