
How Urban Air Mobility is getting ready for passengers: the NTU Singapore case
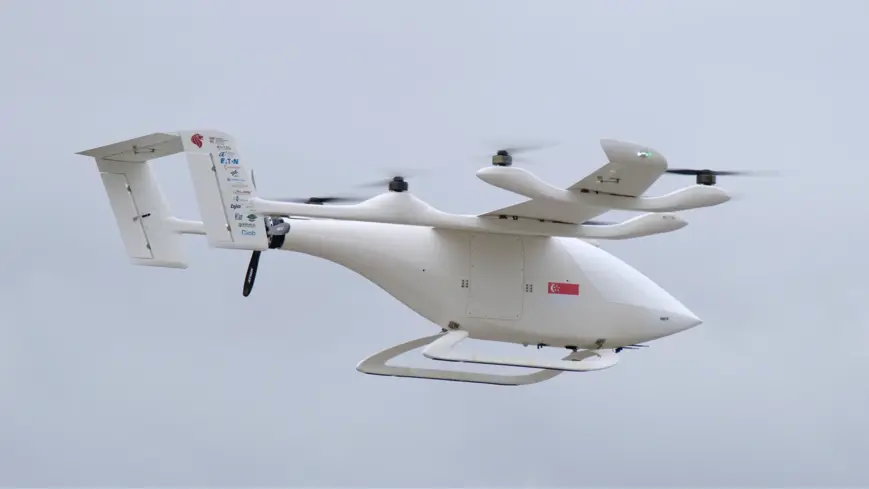
Singapore’s NTU flew its eVTOL prototypes in Germany. See what it means for urban air mobility, and why safety starts in flight control.
August 5, 2014
UVID 2014: The third annual unmanned system conference, scheduled to be held on September 17, 2014, at the Avenue Conference Center, Airport City. The theme of this year’s conference is “Unmanned Vehicles: Global Leadership as a National Mission.” The UVID conference was initiated by the editorial board of Israel Defense and is intended to concentrate, under one roof, a strategic system-wide overview of the field of unmanned vehicles in the air, at sea, and on land to encourage a dialog and develop a common world of knowledge for the extensive community involved in the build-up and employment of this fascinating field.
Embention, a company dedicated to the development of critical systems and products in the field of Unmanned Aircraft Systems (UAS), attends UVID Israel Defense 2014 with its high-performance autopilot for control of UAVs, RPAS, and drones, Veronte Autopilot 1x. This control system is completely customizable to the needs of the users, and they can include some advanced features such as RTK, onboard vision, custom flight phases, etc.
Seniors from the MOD | Director of the Unmanned Warfare Program of the DOD | NATO Joint Air Power Competence Center | Head of Operations of the Fire & Rescue Commission | Director of the UAV Systems department of the Civil Aviation Authority | Senior officials from the IDF and Defense Industries | INSS | FROST & SULLIVAN | XLN ISRAEL
Receive news & updates
Singapore’s NTU flew its eVTOL prototypes in Germany. See what it means for urban air mobility, and why safety starts in flight control.
Embention presents Veronte KAI upgrades, expands defense partnerships, and showcases autonomous flight avionics at MSPO Poland and UNVEX Spain.
Discover Veronte KAI 2.2 with AI-based PNT, terminal guidance and scalable production for one-way drones in contested environments.
