1x
SAIL I-IV | Fail-Safe
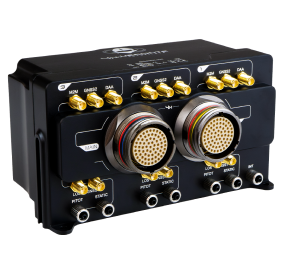
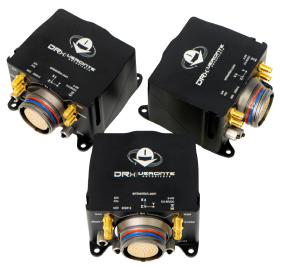
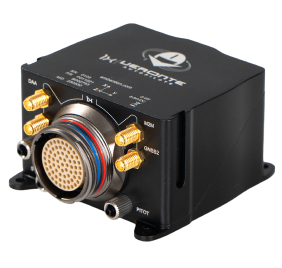
More info Multirotor drones are known for their vertical flight precision, hovering ability, and mechanical simplicity. Veronte Autopilot provides advanced control capabilities for all multirotor layouts, offering modular integration, customizable logic, and safety-critical features suited for commercial and tactical operations.
The most common geometry, supported by default.
Platforms with increased thrust and redundancy.
Supported with advanced control logic for yaw and pitch balance.
Compatible with stacked motor geometries and novel airframe designs.
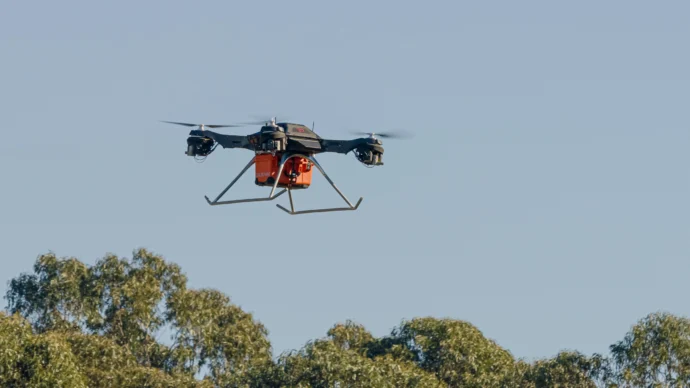
Vertical takeoff is automatic with environmental adaptation and configurable altitude/speed profiles. Multiple preconditions (arming state, GNSS fix, flight mode) can be enforced.

Landing in both static and moving platforms is possible with the use of Veronte Autopilot. The integration with relative positioning sensors (vision, IR, ultrasound, etc.) enables rendezvous algorithms.
Real-time attitude control ensures stability in turbulence and high wind. Veronte’s algorithms allow precise altitude hold, position lock, and autonomous flight path execution with rapid response to commands or sensor feedback.
Integrates redundant IMUs, dual GNSS, and multiple power rails being available in redundant autopilot configurations. Includes real-time monitoring, emergency mode transitions, and safe-throttle idle handling. Meets UAV safety protocols and supports certification processes.